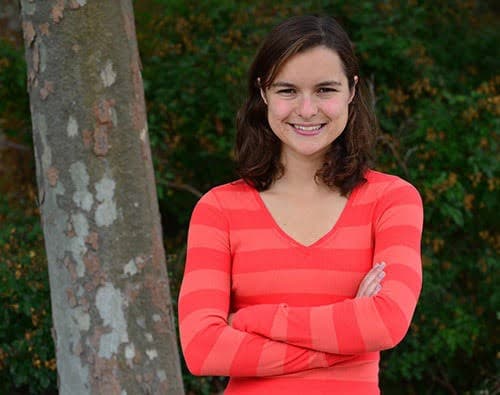
Chelsea Finn
Assistant Professor of Computer Science and Electrical Engineering, Stanford University
A robotics and machine-learning researcher studying how systems can learn adaptable behavior from limited experience.
Biography
Chelsea Finn is a computer scientist whose research focuses on robots that learn and adapt. She studied electrical engineering and computer science at MIT and completed her doctorate at the University of California, Berkeley, in 2018. Her graduate research connected machine learning with the practical challenges of controlling physical systems.
Finn co-authored Model-Agnostic Meta-Learning, published in 2017. The method explored training models so they could adapt quickly to a new task using a small amount of additional experience. Its influence extended beyond robotics into a broader body of research on learning across tasks and the relationship between prior training and later adaptation.
At Stanford University, she leads research on robot learning, including how systems can acquire useful behavior from data and interaction. This work must address variability in environments, incomplete observations, and the difficulty of collecting physical experience at scale. It connects questions about generalization with concrete requirements for reliable action.
Finn also co-founded Physical Intelligence, a company developing general-purpose models for robotics. Her career combines academic research with efforts to build systems that can operate across different robots and tasks. Her contribution is particularly relevant to the gap between a model's performance in a controlled experiment and its ability to learn useful behavior in a changing physical world.
Notable contributions
Co-authored Model-Agnostic Meta-Learning
Developed a method for training models to adapt quickly to new tasks.
Built a Stanford robot-learning research program
Leads academic research on learning and adaptation in robotic systems.
Co-founded Physical Intelligence
Helped establish a company developing general-purpose robotic intelligence.