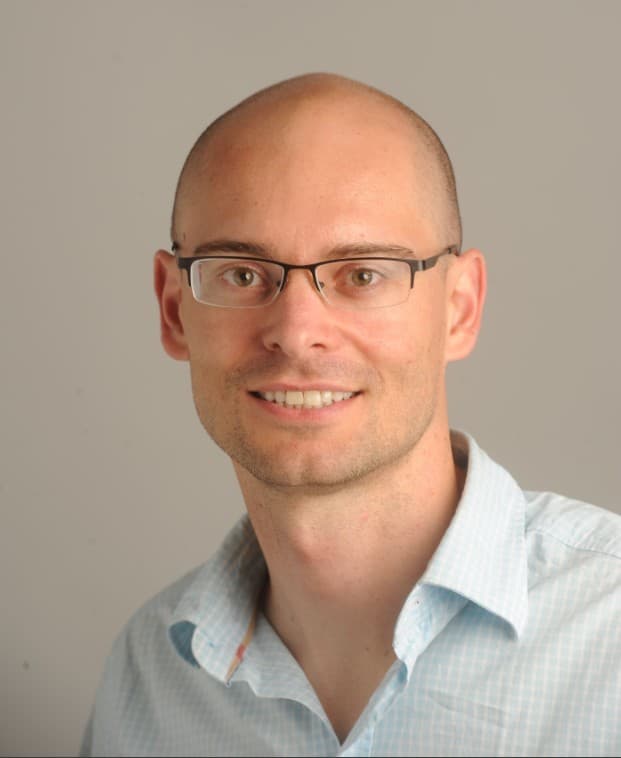
Pieter Abbeel
Professor at UC Berkeley and Distinguished Scientist at Amazon
A robot-learning researcher who develops methods for learning behavior from demonstrations and experience, linking academic research with industrial robotics.
Biography
Pieter Abbeel is a researcher in machine learning and robotics at the University of California, Berkeley. He earned his doctorate at Stanford University under Andrew Ng and joined Berkeley in 2008. He directs the Berkeley Robot Learning Lab and has helped lead the Berkeley Artificial Intelligence Research laboratory.
Abbeel’s work investigates how machines can learn useful behavior rather than rely entirely on hand-written control rules. His research with Ng on apprenticeship learning used inverse reinforcement learning to infer useful objectives from demonstrations. Later work explored deep reinforcement learning, imitation learning, and generalization across robotic tasks.
He also co-founded Covariant, bringing learning-based methods into industrial robotics, and has worked with Amazon alongside his academic role. His influence combines algorithms, laboratory leadership, and the training of researchers. The central problem across this work is how robots can acquire skills that remain useful when objects, environments, and task requirements change.
Notable contributions
Co-authored apprenticeship learning research
Developed an inverse reinforcement learning approach for learning useful behavior from expert demonstrations.
Co-founded Covariant
Helped establish the robotics company applying machine learning to industrial manipulation.